I design mechanisms
that grip, sense,
and move.
Mechanical engineer focused on mechatronics and robotics: adaptive grippers, motor control, and thermal systems, built on a foundation of CNC machining, CAD, and hands-on lab work at Boston University.
Boston University
MS Mechanical Engineering, focus in mechatronics and robotics.
RASTIC, Boston University
Graduate research assistant: robotics lab operations and instruction.
Boston Robotics Club
Mechanical engineer & machinist: CNC machining and end-effector design.
Mass Robotics Award
1st place ($10,000) & Audience Appreciation ($1,000), $11,000 total.
Six builds, one habit: take the mechanism apart until it's simple.
Grippers, actuators, and control systems: designed in CAD, machined by hand, and tuned on the bench.
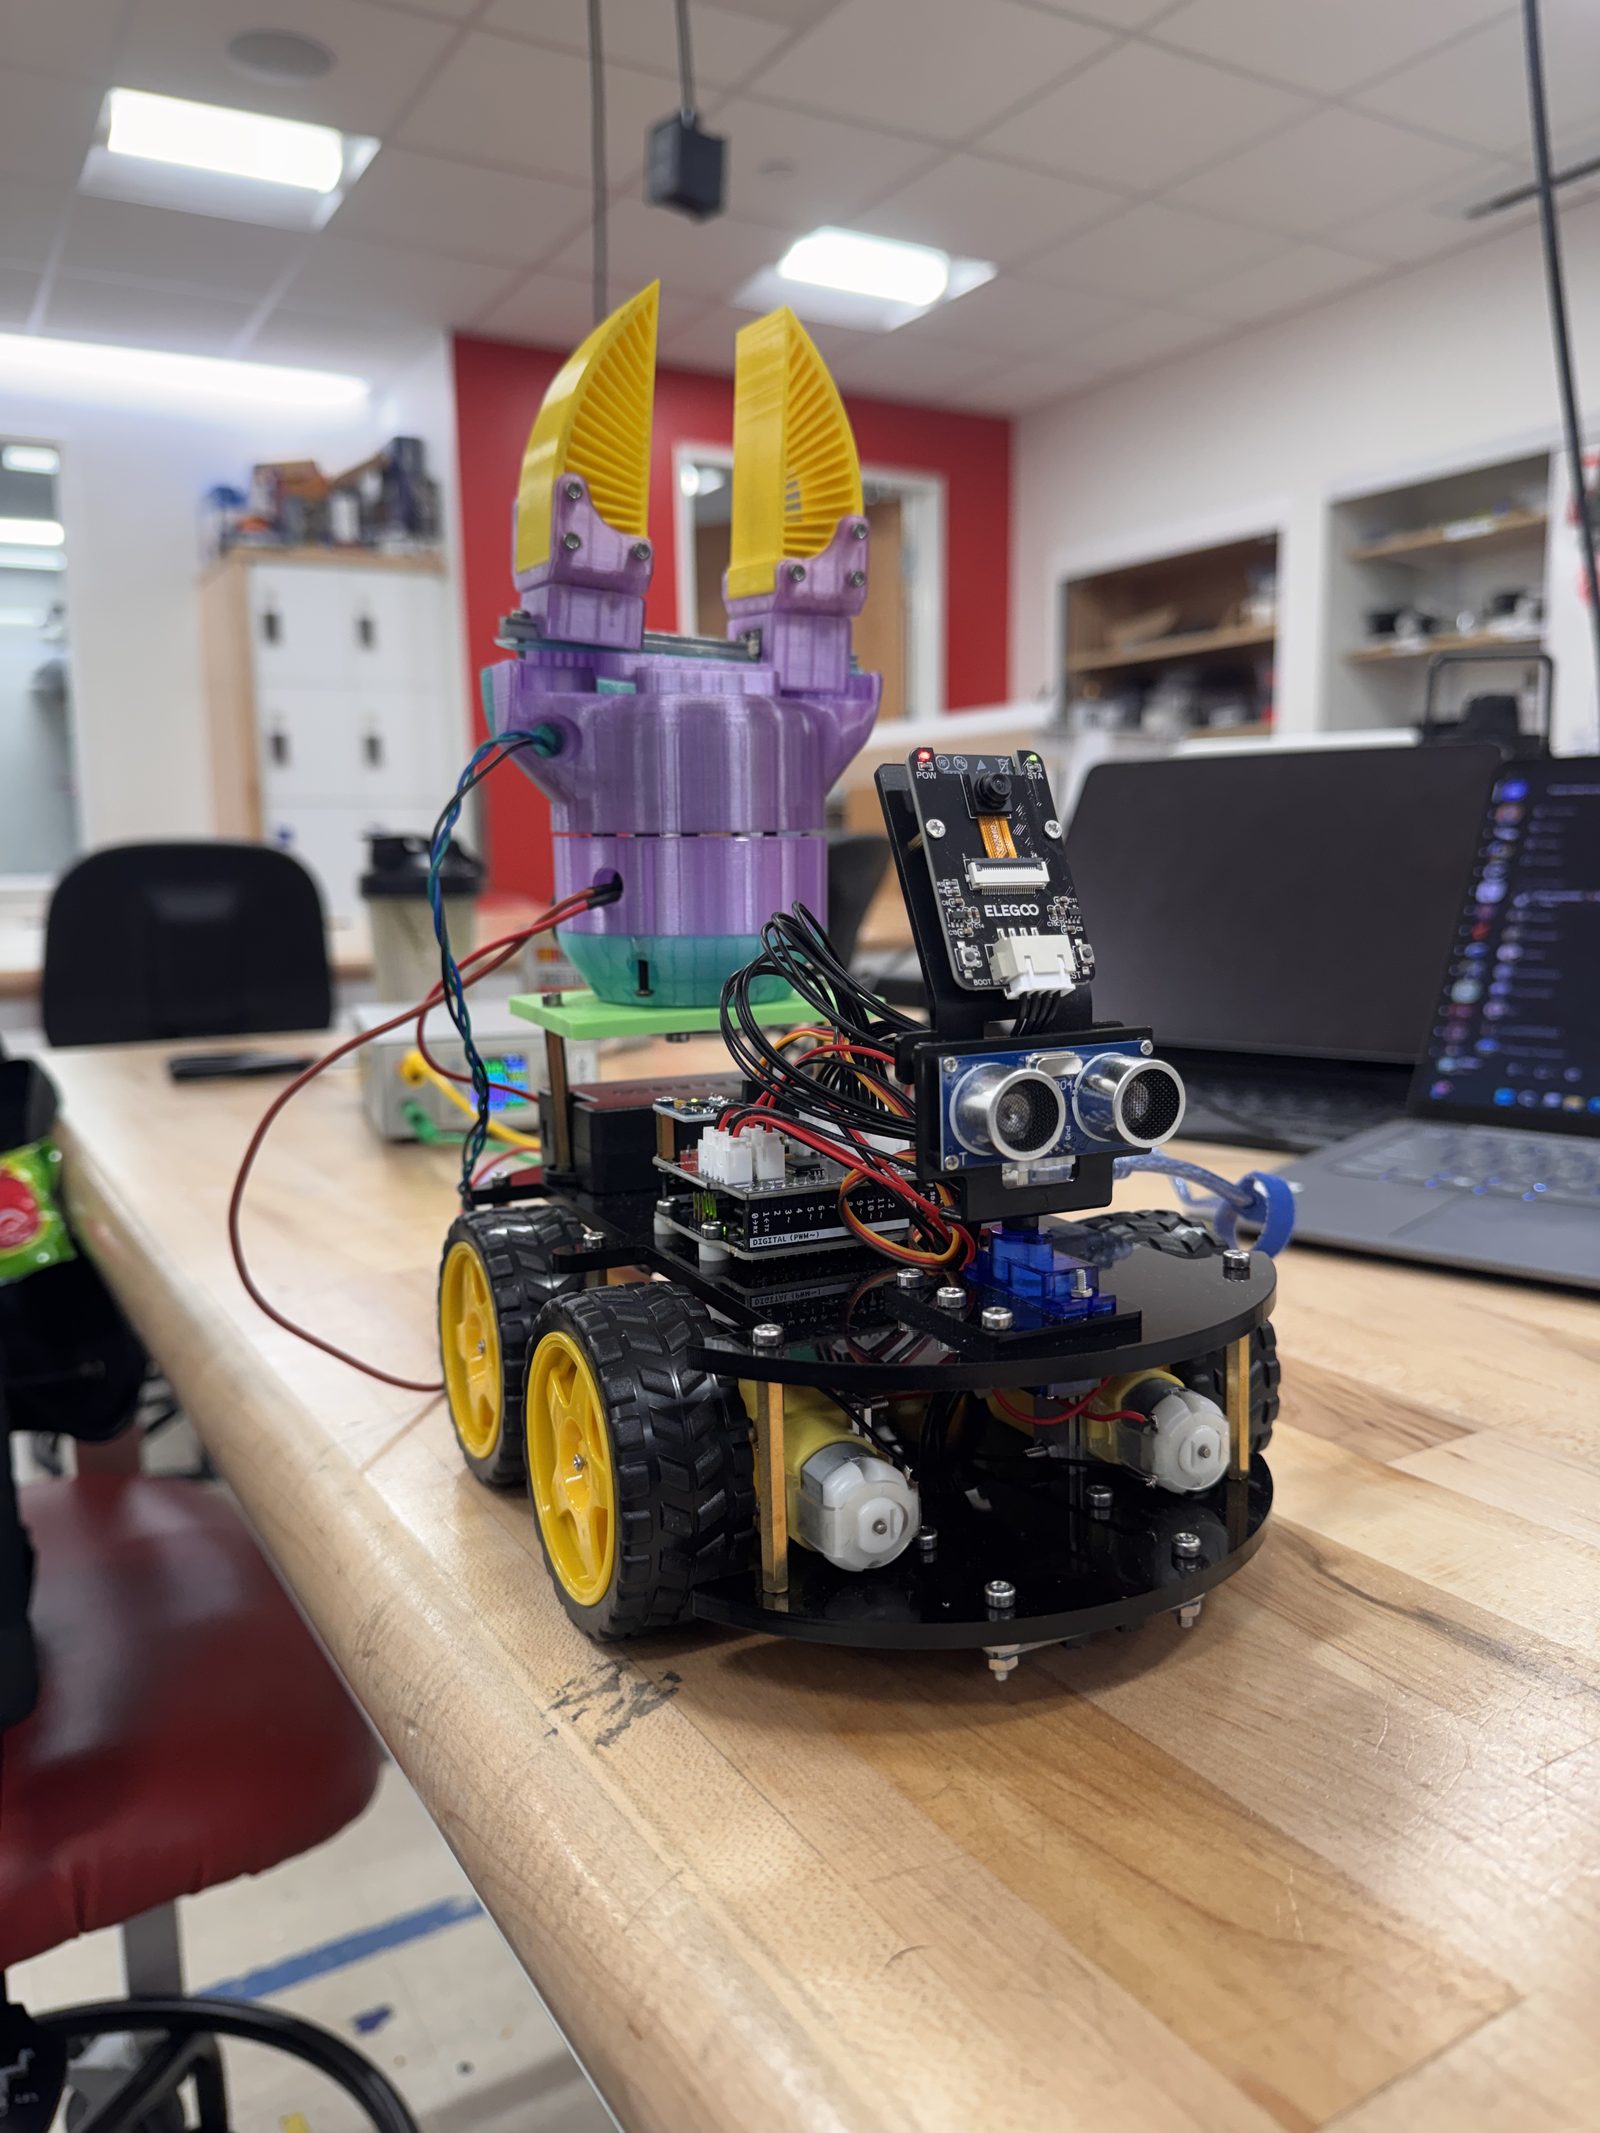
Adaptive Fin-Ray Gripper
moteus-c1 R1.2 · CAN-FD · mj5208A compliant, self-conforming end effector built around a CAN-FD servo controller and a from-scratch actuation pipeline.
Read the build → PRJ-02Fruit-Picking Robotic Arm
6-JOINT · CNC AL 6061 · BOSTON ROBOTICS CLUBMachined and assembled the arm structure; designed the fin-ray end effector for a tomato-harvesting competition entry.
Read the build → PRJ-03SMOC Thermal Regulator
ESP32-S3 · DUAL-ZONE · SMOC CONTROLA dual-zone heater platform controlling temperature with Shell Multivariable Optimizing Control, identified from PRBS test data.
Read the build → PRJ-04Rotary Vane Pump
ME 559 · TEAM PROJECT · GD&TA positive-displacement pump built with a three-person team: eccentric rotor, sliding vanes, a full GD&T drawing package.
Read the build → PRJ-05Rehab Grip-Pressure Sensor
ME 571 · FLEX SENSOR · LCD READOUTA wearable flex sensor with a live LCD pressure readout, built to gauge finger strength during extremity rehabilitation.
Read the build → PRJ-06Pneu-Net Soft Robot
ME 568 · SILICONE · SYRINGE-ACTUATEDA self-propelling pneu-net soft robot, cast in silicone and inflated section by section with hand-driven syringes.
Read the build →